Block 1 · 15 credits. Electrical principles, power electronics and motors: how energy gets from a battery or the grid into a robot’s motors, and how to choose the parts that do it.
You’ll be able to: describe the main types of electric motor · calculate electrical quantities in actuator circuits · justify a motor choice from the application’s requirements · test motors against those requirements.
Assessment: A1 computer-based test, 30% (week 5) · A2 individual report built on the lab work, 70% (week 9).
Week 1: circuit fundamentals
- Electrical quantities: charge, current, voltage, resistance, power, energy and efficiency
- Kirchhoff’s laws: KCL, KVL, series and parallel, dividers and the power balance
- Voltage node method: one equation for circuits with several sources
- Wheatstone bridge and thermistors: measuring small changes in resistance
- Power electronics overview: converter types, the components, and a MOSFET as a switch
Week 2: matrices, mesh analysis and transients
- Matrices and Cramer’s rule: determinants and solving simultaneous equations
- Mesh analysis: every current in a multi-loop circuit at once
- RC transients: charging and discharging, and the time constant τ
Week 3: from the wall socket to the motor
-
AC values: peak, RMS and average
-
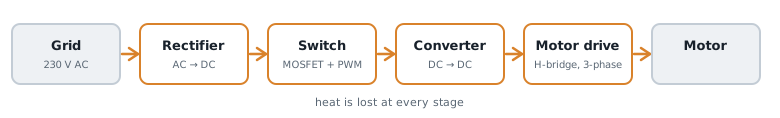
Bridge rectifiers: AC to DC, smoothing, ripple and heat
-
Power switches: relay, SSR, BJT, MOSFET and IGBT
-
PWM: controlling power by switching fast
-
MOSFET power loss: conduction and switching losses
-
Thermal design and heatsinks: thermal resistance and sizing a heatsink
-
DC-DC converters: buck and boost
-
Motor drives: H-bridges, inverters and stepper drivers
-
Week 3 interactive: the whole week on one page, with live models and calculators
Week 4: motors for robotics
- Electric motors and DC motor types: how a DC motor makes torque, back-EMF, PMDC, shunt and series, losses and heat
- DC motor performance and selection: the calculation chain, gearboxes, and checking a motor against a requirement
- Stepper motors: steps, microstepping, unipolar vs bipolar, and the forward problem
- Sizing a drive motor: from a robot’s mass, speed and slope to the torque and power its motor needs
Revision
- WM1AD practice questions: test-style questions with hidden worked answers
- WM1AD formula sheet: every formula from the module on one page
- glossary: every symbol across the course